Real hardware, safe to learn on
Every new program runs simulation first, then on a gantry, then on the floor. Physical and remote e-stops, a named operator and spotter, and a session log keep the lab safe.
Safety SOP enforced
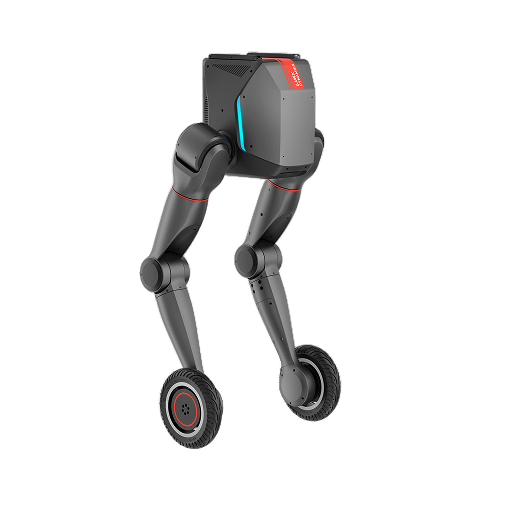
TRON1 is a multi-modal biped robot with an open SDK, a 12-module curriculum and a complete sim-to-real pipeline. Collie delivers it with on-site faculty certification and ongoing local support, so your lab is teaching from week one.
Students learn the same tools industry uses, on hardware they can actually run their own code on, with safety and assessment designed in from the start.
Every new program runs simulation first, then on a gantry, then on the floor. Physical and remote e-stops, a named operator and spotter, and a session log keep the lab safe.
Official LimX repositories cover the full train-to-deploy path, alongside NVIDIA Isaac Lab, MuJoCo, Gazebo and ROS 2, so graduates take skills straight into industry.
Swap between point-foot, sole-foot and wheel-foot ends to compare locomotion strategies (walking, balancing and rolling) on a single robot chassis.
Add the arm, sensor/LiDAR and voice-interaction kits when your programme is ready for mobile manipulation, SLAM and language-driven embodied AI agents.
Run sample joint-move programs and watch kinematics in real time in PlotJuggler or RViz.
Train locomotion policies with reinforcement learning across thousands of parallel environments.
A policy that works in two physics engines is far more likely to work reliably on hardware.
Deploy with Python or ROS 2 while the robot hangs safely, feet just millimetres off the floor.
Run in a marked test zone with a spotter, then review the rosbag and log the session.
Mapped directly to the official LimX curriculum and structured so students progress systematically from first power-on to an integrated capstone application.
For introductory and second-year engineering students
For senior undergraduates and capstone teams
Optional, for advanced master's and capstone research
Prevent laboratory equipment collisions and guarantee safe undergraduate exploration with Collie's certified operational sign-off sequence.
Runs to completion in virtual sim, results fully recorded.
Cross-verified in MuJoCo physics engine before compile.
Suspended on lab tether, remote physical e-stop verified.
Zone perimeter cleared, designated spotter on duty.
Full rosbag saved to lab server, session log certified.
Every graduate trains on battle-tested frameworks directly transferable to enterprise robotics ventures and leading research institutions.
| Dimensions | ≤ 392 × 420 × 845 mm |
|---|---|
| Net weight | ≤ 20 kg |
| Payload | ≤ 10 kg |
| Speed | < 1 m/s legged · ≤ 3 m/s wheeled |
| Terrain adaptability | ≤ 30° slopes · ≤ 20 cm obstacles |
| Battery | Up to 2 h · quick swap · < 1 h fast charge (20–80%) |
| Onboard compute | 12th Gen Intel i3 · 16 GB · 512 GB |
| Actuators | 30 N·m rated · 80 N·m peak torque |
| Expansion ports | USB 3.0 · GbE · 24 V / 100 W power port |
| Remote control | Handheld controller, 50 m range, remote e-stop |
* Specifications as certified by LimX Dynamics; measured under standard laboratory conditions.
We certify 2–4 of your lecturers and lab technicians first, so your team runs student modules completely independently, with Collie specialists one call away.
Short real-world clips of TRON1 on the move, the kind of behaviour your students will be programming.


Yes. About 80% of lab coursework happens in simulation directly on students’ workstations. Student teams book 30-minute real-robot test slots only after their code passes Gates 1 and 2 in simulation. A single TRON1 chassis easily supports 25 to 40 students per semester.
Standard student laptops or lab desktops with Ubuntu 22.04 LTS, 16 GB RAM and 512 GB storage are sufficient for SDK, ROS 2 and Gazebo modules. For Tier 2 reinforcement learning policy training, your department requires at least one dedicated workstation equipped with an NVIDIA RTX GPU (12 GB+ VRAM) running NVIDIA Isaac Sim and Isaac Lab.
No prior kinematics or physical robotics experience is needed. Tier 1 starts from first power-on, Linux fundamentals and basic ROS 2 publish-subscribe loops. Tiers 2 and 3 build systematically toward advanced reinforcement learning, sensor fusion, computer vision, local LLM inference and SLAM.
Collie provides official global university distribution with certified customs handling across Southeast Asia, North America, Europe, Australia and the Middle East. On-site faculty training is conducted by bilingual robotics engineers, backed by rapid hardware swap logistics from Singapore and regional hubs.
Tell us about your lab and we’ll recommend the right setup.
Tell Us Your Needs arrow_forward